Sukhoi SuperJet 100 "EgyptAir" Просмотр ZIP-архива
Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/Aircraft.cfg
//Sukhoi SuperJet 100 (RRJSuk) V. 2009.04.4 VIRTUAL AIRWAY.
//Model by RRJSuk.
//Flight Dynamics: RRJSuk feat. VIRTUAL AIRWAY.
//Master Texture Designer: VIRTUAL AIRWAY.
//Test Pilots: VIRTUAL AIRWAY M. Vinogradov.
//======================================================================================

[fltsim.0]
title=SuperJet 100 "EgyptAir"
sim=SSJ100
model=
panel=
sound=
texture=

kb_checklists=
kb_reference=

ui_manufacturer=Sukhoi SuperJet 100
ui_type=Sukhoi
ui_variation=SuperJet 100 "EgyptAir"

atc_heavy=0
atc_id=SU-AEG
atc_airline=EgyptAir
atc_flight_number=AEG
atc_parking_types=GATE, RAMP

description=VIRTUAL AIRWAY - Sukhoi SuperJet 100 \nVersion 2009.04.4\n\nModel Designer\n RRJSuk\n\nFlight Dynamics\n VIRTUAL AIRWAY\n\nMaster Texture Designer\nVIRTUAL AIRWAY\n\nTest Pilots\nM. Vinogradov VIRTUAL AIRWAY

//======================================================================================

[General]
atc_type=SUKHOI
atc_model=RRJ100
editable=0
performance=Cruise Speed\t.82 Mach\nMaximum Range\t2,059 nm\nService Ceiling\t36,089 ft\nMax Takeoff Weight\t138,500 lb\nSeating\t\t147 to 168\n

//======================================================================================

[pitot_static]
vertical_speed_time_constant = 1

//======================================================================================

[WEIGHT_AND_BALANCE]
max_gross_weight = 150000
empty_weight = 74170

reference_datum_position     =   0, 0, 0
empty_weight_CG_position     =  -5, 0, 0

max_number_of_stations = 50

station_load.0 =   "170.0,  41.0, -1.5,	0.0, Pilot"              //Weight (lbs), longitudinal, lateral, vertical positions from datum (feet)
station_load.1 =   "170.0,  41.0,  1.5,	0.0, Co-Pilot"           //Weight (lbs), longitudinal, lateral, vertical positions from datum (feet)
station_load.2 =   "510.0,   0.0,  0.0,	0.0, Crew"               //Weight (lbs), longitudinal, lateral, vertical positions from datum (feet)
station_load.3 =  "1360.0,  25.5,  0.0,	0.0, First Class"        //Weight (lbs), longitudinal, lateral, vertical positions from datum (feet)
station_load.4 =  "8160.0,  11.0,  0.0,	0.0, Coach 3-10"         //Weight (lbs), longitudinal, lateral, vertical positions from datum (feet)
station_load.5 =  "8160.0, -10.0,  0.0,	0.0, Coach 11-18"        //Weight (lbs), longitudinal, lateral, vertical positions from datum (feet)
station_load.6 =  "7140.0, -30.5,  0.0,	0.0, Coach 19-25"        //Weight (lbs), longitudinal, lateral, vertical positions from datum (feet)
station_load.7 = "10000.0,  20.5,  0.0,	0.0, Forward Baggage"    //Weight (lbs), longitudinal, lateral, vertical positions from datum (feet)
station_load.8 =  "4000.0, -27.5,  0.0,	0.0, Aft Baggage"        //Weight (lbs), longitudinal, lateral, vertical positions from datum (feet)

;Moments of Inertia
empty_weight_pitch_MOI  = 3172439
empty_weight_roll_MOI   = 2262183
empty_weight_yaw_MOI    = 3337024
empty_weight_coupled_MOI = 0.000
CG_forward_limit= 0.000
CG_aft_limit= 1.000

//======================================================================================

[flight_tuning]
cruise_lift_scalar     =1.000
parasite_drag_scalar   =1.201
induced_drag_scalar    =1.201
elevator_effectiveness =1.500
aileron_effectiveness  =0.350
rudder_effectiveness   =0.251
pitch_stability        =1.000
roll_stability         =1.000
yaw_stability          =1.000

elevator_trim_effectiveness =0.751
aileron_trim_effectiveness  =0.501
rudder_trim_effectiveness   =0.501

//======================================================================================

[GeneralEngineData]
engine_type = 1
Engine.0 = 4.75, -16.1, -4.5
Engine.1 = 4.75,  16.1, -4.5
fuel_flow_scalar = 1
min_throttle_limit = -0.25
max_contrail_temperature = -30

//======================================================================================

[TurbineEngineData]
fuel_flow_gain = 0.002
inlet_area = 19.6
rated_N2_rpm = 29920
static_thrust = 24500
afterburner_available = 0
reverser_available = 1

//======================================================================================

[jet_engine]
thrust_scalar = 1.0

//======================================================================================

[electrical]
                ;BusType, MaxAmpLoad, MinVoltage       BusTypes:0=MainBus,1=AvionicsBus,2=BatteryBus,3=HotBatteryBus,4-7=Generator/AlternatorBus(1-4)
flap_motor         = 0, 5 , 17.0
gear_motor         = 0, 15, 17.0
autopilot          = 0, 5 , 17.0
avionics_bus       = 0, 5,  17.0
avionics           = 1, 5 , 17.0
pitot_heat         = 0, 2 , 17.0
additional_system  = 0, 2,  17.0
marker_beacon      = 1, 2 , 17.0
gear_warning       = 0, 2 , 17.0
fuel_pump          = 0, 5 , 17.0
starter1           = 0, 20, 17.0
light_nav          = 0, 5 , 17.0
light_beacon       = 0, 5 , 17.0
light_landing      = 0, 5 , 17.0
light_taxi         = 0, 5 , 17.0
light_strobe       = 0, 5 , 17.0
light_panel        = 0, 5 , 17.0

        //0  Class                        <0=none,1=wheel, 2=scrape, 3=float>
        //1  Longitudinal Position        (feet)
        //2  Lateral Position             (feet)
        //3  Vertical Position            (feet)
        //4  Impact Damage Threshold      (Feet Per Minute)
        //5  Brake Map                    (0=None, 1=Left, 2=Right)
        //6  Wheel Radius                 (feet)
        //7  Steer Angle                  (degrees)
        //8  Static Compression           (feet)  (0 if rigid)
        //9  Max/Static Compression Ratio
        //10 Damping Ratio                (0=Undamped, 1=Critically Damped)
        //11 Extension Time               (seconds)
        //12 Retraction Time              (seconds)
        //13 Sound Type
        //14 Airspeed limit for retraction     (KIAS)
        //15 Airspeed that gear gets damage at (KIAS)

//======================================================================================

[contact_points]
point.0=1,  40.00,   0.00, -11.30, 1181.1, 0, 1.442, 55.92, 0.6, 2.5, 0.9, 6.0, 6.0, 0, 220.0, 250.0
point.1=1,  -7.27,  -8.58, -11.80, 1574.8, 1, 1.442,  0.00, 1.0, 2.5, 0.9, 6.5, 6.5, 2, 220.0, 250.0
point.2=1,  -7.27,   8.58, -11.80, 1574.8, 2, 1.442,  0.00, 1.0, 2.5, 0.9, 7.0, 7.0, 3, 220.0, 250.0

point.3=2, -14.17, -47.33,  0.00,  787.4, 0, 0.000,  0.00, 0.0, 0.0, 0.0, 0.0, 0.0, 5, 0.0, 0.0
point.4=2, -14.17,  47.33,  0.00,  787.4, 0, 0.000,  0.00, 0.0, 0.0, 0.0, 0.0, 0.0, 6, 0.0, 0.0
point.5=2, -54.00,   0.00,  2.83,  787.4, 0, 0.000,  0.00, 0.0, 0.0, 0.0, 0.0, 0.0, 9, 0.0, 0.0
point.6=2,  42.67,   0.00, -3.75,  787.4, 0, 0.000,  0.00, 0.0, 0.0, 0.0, 0.0, 0.0, 4, 0.0, 0.0

max_number_of_points = 21

static_pitch=0.03
static_cg_height=10.50
gear_system_type=1

//======================================================================================

[gear_warning_system]
gear_warning_available = 1
pct_throttle_limit =  0.1
flap_limit_idle    =  5.0
flap_limit_power   = 25.5

//======================================================================================

[brakes]
parking_brake = 1
toe_brakes_scale = 0.35

//======================================================================================

[hydraulic_system]
normal_pressure = 3000.0
electric_pumps  = 0
engine_map      = 1,1,0,0

//======================================================================================

[Views]
eyepoint=43.7, -1.31, 3.7

//======================================================================================

[flaps.0]       //Trailing Edge Flaps
type             = 1                                    // 1 - tail, 2 - lead
span-outboard    = 0.8                                  // 0.0 .. 1.0
extending-time   = 10                                   // seconds
flaps-position.0 = 0                                    // degrees
flaps-position.1 = 1                                    // degrees
flaps-position.2 = 2                                    // degrees
flaps-position.3 = 5                                    // degrees
flaps-position.4 = 10                                   // degrees
flaps-position.5 = 15                                   // degrees
flaps-position.6 = 25                                   // degrees
flaps-position.7 = 30                                   // degrees
flaps-position.8 = 40                                   // degrees
damaging-speed   = 250                                  // KIAS
blowout-speed    = 300                                  // KIAS
lift_scalar = 1.0
drag_scalar = 1.0
pitch_scalar= 1.0
system_type = 1                                         //Hydraulic

[flaps.1]       //Inboard Leading Edge Flaps
type             = 2                                    // 1 - tail, 2 - lead
span-outboard    = 0.8                                  // 0.0 .. 1.0
extending-time   = 5                                    // seconds
flaps-position.0 = 0                                    //
flaps-position.1 = 1.0                                  //
damaging-speed   = 250                                  // KIAS
blowout-speed    = 300                                  // KIAS
lift_scalar = 1.0
drag_scalar = 1.0
pitch_scalar= 1.0
system_type = 1                                         //Hydraulic


[flaps.2]       //Outboard Leading Edge Slat
type             = 2                                    // 1 - tail, 2 - lead
span-outboard    = 0.8                                  // 0.0 .. 1.0
extending-time   = 6                                    // seconds
flaps-position.0 = 0                                    //
flaps-position.1 = 0.5                                  //
flaps-position.4 = 1.0                                  //
damaging-speed   = 250                                  // KIAS
blowout-speed    = 300                                  // KIAS
lift_scalar = 1.0
drag_scalar = 1.0
pitch_scalar= 1.0
system_type = 1                                         //Hydraulic

//======================================================================================

[Radios]
// Radio Type = availiable, standby frequency, has glide slope
Audio.1       = 1
Com.1         = 1, 1
Com.2         = 1, 1
Nav.1         = 1, 1, 1
Nav.2         = 1, 1, 0
Adf.1         = 1
Transponder.1 = 1
Marker.1      = 1

//======================================================================================

[keyboard_response]
elevator = 100, 200
aileron  = 100, 200
rudder   = 100, 200

//======================================================================================

[direction_indicators]
//1 Type: 0=None, 1=Vacuum Gyro, 2=Electric Gyro, 3=Electro-Mag Slaved Compass, 4=Slaved to another
//2 Indicator number of slaving indicator if Type = 4
direction_indicator.0=3,0

//======================================================================================

[attitude_indicators]
//Type: 0=None, 1=Vacuum Gyro, 2=Electric Gyro
attitude_indicator.0 = 1

//======================================================================================

[turn_indicators]
//Type: 0=None, 1=Electric Gyro, 2= Vacuum Gyro
turn_indicator.0=0,0

//======================================================================================

[exits]
number_of_exits = 2
exit_rate.0 = 0.4                               ;Percent per second
exit_rate.1 = 0.4                               ;Percent per second

//======================================================================================

[EFFECTS]
wake=fx_wake
water=fx_spray
dirt=fx_tchdrt
concrete=fx_sparks
touchdown=fx_tchdwn, 1

//======================================================================================

[autopilot]
autopilot_available=                                 1
flight_director_available=                           1
default_vertical_speed=                              1500
autothrottle_available=                              1
autothrottle_arming_required=                        1
autothrottle_max_rpm =                               101.8
autothrottle_takeoff_ga=                             1
pitch_takeoff_ga =                                   0.000
use_no_default_pitch = 1 // 0 = Default to current pitch mode, 1 = No default pitch mode.
use_no_default_bank =  1 // 0 = Default to Wing Leveler mode, 1 = No default bank mode.
default_pitch_mode=0
default_bank_mode=0
max_pitch=                                           10.0
max_pitch_acceleration=                              1.0
max_pitch_velocity_lo_alt=                           2.0
max_pitch_velocity_hi_alt=                           0.3
max_pitch_velocity_lo_alt_breakpoint=                7000.0
max_pitch_velocity_hi_alt_breakpoint=                24000.0
max_bank=                                            22.0
max_bank_acceleration=                               1.2
max_bank_velocity=                                   1.5
max_throttle_rate=                                   0.028
nav_proportional_control=                            9.0
nav_integrator_control=                              0.25
nav_derivative_control=                              0.0
nav_integrator_boundary=                             2.5
nav_derivative_boundary=                             0.0
gs_proportional_control=                             9.52
gs_integrator_control=                               0.26
gs_derivative_control=                               0.0
gs_integrator_boundary=                              0.7
gs_derivative_boundary=                              0.0
yaw_damper_gain=                                     1.0

//======================================================================================

[fuel]
Center1    = 0,   0, 0, 3203, 0                 //Longitudinal (feet), Lateral (feet), Vertical (feet), Usable(gallons), Unusable (gallons)
LeftMain  = -3, -19, 0, 1880, 0                 //Longitudinal (feet), Lateral (feet), Vertical (feet), Usable(gallons), Unusable (gallons)
RightMain = -3,  19, 0, 1880, 0                 //Longitudinal (feet), Lateral (feet), Vertical (feet), Usable(gallons), Unusable (gallons)
fuel_type = 2                                   //Fuel type: 1 = Avgas, 2 = JetA
number_of_tank_selectors = 1
electric_pump=0

//======================================================================================

[airplane_geometry]
wing_area               = 1137.0                //Square feet
wing_span               = 94.75                 //Feet
wing_root_chord         = 18.0                  //Feet
wing_dihedral           = 6.2                   //Degrees
wing_incidence          = 1.0                   //Degrees
wing_twist              = -0.5                  //Degrees
oswald_efficiency_factor= 0.75                  //Measure of lift effeciency of wing
wing_winglets_flag      = 0                     //Are winglets available?
wing_sweep              = 25.0                  //Degrees, wing leading edge
wing_pos_apex_lon       = 8.0                   //Feet, longitudinal distance from reference point, negative going aft
wing_pos_apex_vert      = 0.0                   //Feet, vertical distance from reference point, positive going up
htail_area              = 338.0                 //Square feet
htail_span              = 41.7                  //Feet
htail_pos_lon           = -35.0                 //Feet, longitudinal distance from reference point, negative going aft
htail_pos_vert          = 0.0                   //Feet, vertical distance from reference point, positive going up
htail_incidence         = 0.0                   //Degrees
htail_sweep             = 30.0                  //Degrees, horizontal tail leading edge
vtail_area              = 224.0                 //Square feet
vtail_span              = 20.0                  //Feet, tip to body
vtail_sweep             = 35.0                  //Degrees, vertical tail leading edge
vtail_pos_lon           = -35.8                 //Feet, longitudinal distance from reference point, negative going aft
vtail_pos_vert          = 5.8                   //Feet, vertical distance from reference point, positive going up
elevator_area           = 70.5                  //Square feet
aileron_area            = 26.9                  //Square feet
rudder_area             = 56.2                  //Square feet
elevator_up_limit       = 22.5                  //Degrees
elevator_down_limit     = 19.5                  //Degrees
aileron_up_limit        = 20.0                  //Degrees
aileron_down_limit      = 20.0                  //Degrees
rudder_limit            = 26.0                  //Degrees
elevator_trim_limit     = 20.0                  //Degrees
spoiler_limit           = 60.0                  //Degrees
spoilerons_available    = 1                     //Spoilerons Available?
aileron_to_spoileron_gain = 3                   //Aileron to spoileron gain
min_ailerons_for_spoilerons = 10                //Degrees
min_flaps_for_spoilerons = 0                    //Minimum flap handle position when spoilerons activate

//======================================================================================

[Reference Speeds]
flaps_up_stall_speed    = 142.0                 //Knots True (KTAS)
full_flaps_stall_speed  = 113.0                 //Knots True (KTAS)
cruise_speed            = 465.0                 //Knots True (KTAS)
max_mach                = 0.86
max_indicated_speed     = 340                   //Red line (KIAS)

//======================================================================================

[forcefeedback]
gear_bump_nose_magnitude=3000           ; 0 - 10000
gear_bump_nose_direction=18000          ; 0 - 35999 degrees
gear_bump_nose_duration=250000          ; in microseconds
gear_bump_left_magnitude=2700           ; 0 - 10000
gear_bump_left_direction=35500          ; 0 - 35999 degrees
gear_bump_left_duration=250000          ; in microseconds
gear_bump_right_magnitude=2700          ; 0 - 10000
gear_bump_right_direction=00500         ; 0 - 35999 degrees
gear_bump_right_duration=250000         ; in microseconds
ground_bumps_magnitude1=1300            ; 0 - 10000
ground_bumps_angle1=08900               ; 0 - 35999 degrees
ground_bumps_intercept1=3.0
ground_bumps_slope1=0.20
ground_bumps_magnitude2=200             ; 0 - 10000
ground_bumps_angle2=09100               ; 0 - 35999 degrees
ground_bumps_intercept2=1.075
ground_bumps_slope2=0.035
crash_magnitude1=10000                  ; 0 - 10000
crash_direction1=01000                  ; 0 - 35999 degrees
crash_magnitude2=10000                  ; 0 - 10000
crash_direction2=9000                   ; 0 - 35999 degrees
crash_period2=75000                     ; in microseconds
crash_duration2=2500000                 ; in microseconds

//======================================================================================

[stall_warning]
type=2
19666-Sukhoi-SUPERJET-100-EgyptAir.zip
| Имя файла | Дата | Размер |
|---|---|---|
| Sukhoi SUPERJET 100 EgyptAir/effects/ | 04.04.2009 21:24 | |
| Sukhoi SUPERJET 100 EgyptAir/effects/Opensky_737NG_sparks.fx | 18.03.2006 20:25 | 7 KB |
| Sukhoi SUPERJET 100 EgyptAir/effects/Opensky_beacon.fx | 12.02.2002 17:14 | 3 KB |
| Sukhoi SUPERJET 100 EgyptAir/effects/Opensky_Boeing_vclight.fx | 02.10.2002 11:32 | 1 KB |
| Sukhoi SUPERJET 100 EgyptAir/effects/Opensky_conden.fx | 04.10.2002 00:44 | 3 KB |
| Sukhoi SUPERJET 100 EgyptAir/effects/Opensky_nacelle_refl.fx | 29.09.2002 12:13 | 1 KB |
| Sukhoi SUPERJET 100 EgyptAir/effects/Opensky_nav_yellow.fx | 24.03.2004 13:03 | 3 KB |
| Sukhoi SUPERJET 100 EgyptAir/effects/Opensky_vortex.fx | 08.10.2003 19:14 | 1 KB |
| Sukhoi SUPERJET 100 EgyptAir/effects/Opensky_wing_light.fx | 29.09.2002 12:13 | 1 KB |
| Sukhoi SUPERJET 100 EgyptAir/SJ 100 P.jpg | 04.04.2009 17:13 | 160 KB |
| Sukhoi SUPERJET 100 EgyptAir/SJ 100_1.jpg | 04.04.2009 17:07 | 122 KB |
| Sukhoi SUPERJET 100 EgyptAir/SJ 100_2.jpg | 04.04.2009 17:09 | 149 KB |
| Sukhoi SUPERJET 100 EgyptAir/SJ 100_3.jpg | 04.04.2009 17:11 | 109 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/ | 04.04.2009 21:24 | |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/Aircraft.cfg | 04.04.2009 21:30 | 19 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/model/ | 04.04.2009 21:24 | |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/model/Model.cfg | 27.08.2006 23:01 | 25 B |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/model/RRJSuk.mdl | 17.09.2006 03:24 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/ | 04.04.2009 21:24 | |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/annunciator_640.bmp | 18.04.2001 10:20 | 7 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/forward_1024.bmp | 24.07.2001 07:01 | 534 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/forward_640.bmp | 24.07.2001 07:01 | 209 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/Lear_compass.BMP | 18.04.2001 10:20 | 96 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/Panel.backup | 19.03.2003 11:36 | 4 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/panel.cfg | 31.01.2008 00:29 | 5 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/panel_decal_lear_2.bmp | 19.03.2003 11:36 | 257 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/throttle_quadrant_640.bmp | 18.04.2001 10:20 | 43 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/panel/Thumbs.db | 04.04.2009 15:54 | 21 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/sound/ | 04.04.2009 21:24 | |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/sound/sound.cfg | 18.04.2001 12:19 | 30 B |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/SSJ100.air | 13.06.2003 04:24 | 9 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/ | 04.04.2009 21:24 | |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/Civil Pilot.bmp | 31.01.2003 17:53 | 65 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/Civil Pilot_L.bmp | 17.09.2006 00:31 | 85 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukAsas.bmp | 04.04.2009 16:36 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukAsas_L.bmp | 17.09.2006 00:13 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukFan.bmp | 30.08.2006 23:03 | 43 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukFanH.bmp | 30.08.2006 23:04 | 43 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukInter.bmp | 04.04.2009 16:38 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukInter_L.bmp | 17.09.2006 02:53 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukMap.bmp | 04.04.2009 16:45 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukMap_L.bmp | 04.04.2009 16:36 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukMisc.bmp | 29.08.2006 14:07 | 341 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukMisc_L.bmp | 17.09.2006 00:40 | 341 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukPainel.bmp | 17.09.2006 01:04 | 341 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukPainel_L.bmp | 17.09.2006 01:03 | 341 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukTire.bmp | 19.12.2005 01:23 | 43 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukTireB.bmp | 19.12.2005 00:39 | 192 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukTurb.bmp | 04.04.2009 16:37 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukTurbInt.bmp | 04.04.2009 16:37 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukTurbInt_L.bmp | 16.09.2006 23:15 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/RRJSukTurb_L.bmp | 16.09.2006 23:24 | 1 MB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/Seat.bmp | 31.01.2003 14:50 | 65 KB |
| Sukhoi SUPERJET 100 EgyptAir/SuperJet 100 EgyptAir/texture/Thumbs.db | 04.04.2009 15:32 | 108 KB |
| Sukhoi SUPERJET 100 EgyptAir/ | 04.04.2009 17:23 | |
| avsim_su.diz | 04.04.2009 20:03 | 406 B |
| Итого: | 16 MB | |
Sukhoi SuperJet 100 "EgyptAir"
| Rating: 4.6!
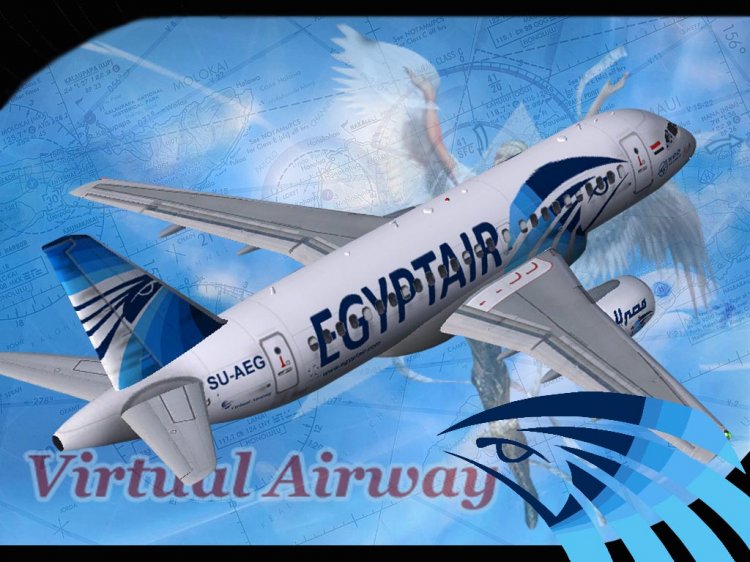
I seriously do not kick it, my second job. Unfortunately, the model leaves much to be desired, but until then, been able to find in nete. Significantly changed the dynamics. The original momentum was just terrible (like flying in fighter). Now, fly like a liner, not the fighters. The panel and sounds have not yet spread (I continue to work on it). For a while I use the cover of the CRJ. Here is a brief and all. TIPS ON MERITS greeting.
→ Size:
2 MB
→ Date:
17 years ago (04.04.2009 21:17)
→ Author:
Модель RRJSuk,. Текстуры и динамика VIRTUAL AIRWAY и RRJSuk.
→ Approved by moderator:
AirArt
→ License:
Freeware - Free version, Unlimited Distribution
→ Downloaded:
3770 time(s)